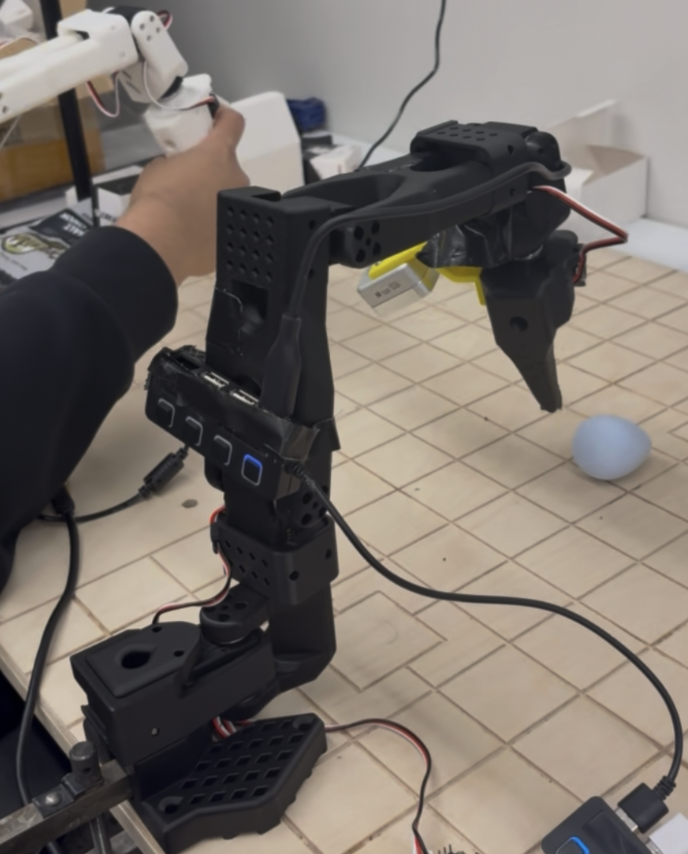
Fine-tuned SmolVLA on 150 real-robot demonstrations across three manipulation tasks and adapted temporal ensembling to its flow-matching inference pipeline, improving deformable-object manipulation success by 40 percentage points.
Last updated: September 2026
Hey! I'm Nithin, a graduate student at the University of Michigan pursuing an MS in Robotics. I'm passionate about developing and bringing ambitious technologies into the real world, whether that's autonomous vehicles, rockets, humanoid robots, or something else!
Prior to my MS, I earned my BSE in Robotics from the University of Michigan, graduating Summa Cum Laude. My experience spans robotics software, perception, controls, systems integration, and cross-functional engineering projects.
Temporal Ensemble Inference for SmolVLA | Website
Fine-tuned SmolVLA on 150 real-robot demonstrations across three manipulation tasks and adapted temporal ensembling to its flow-matching inference pipeline, improving deformable-object manipulation success by 40 percentage points.
PPO for Robotic Grasping | GitHub
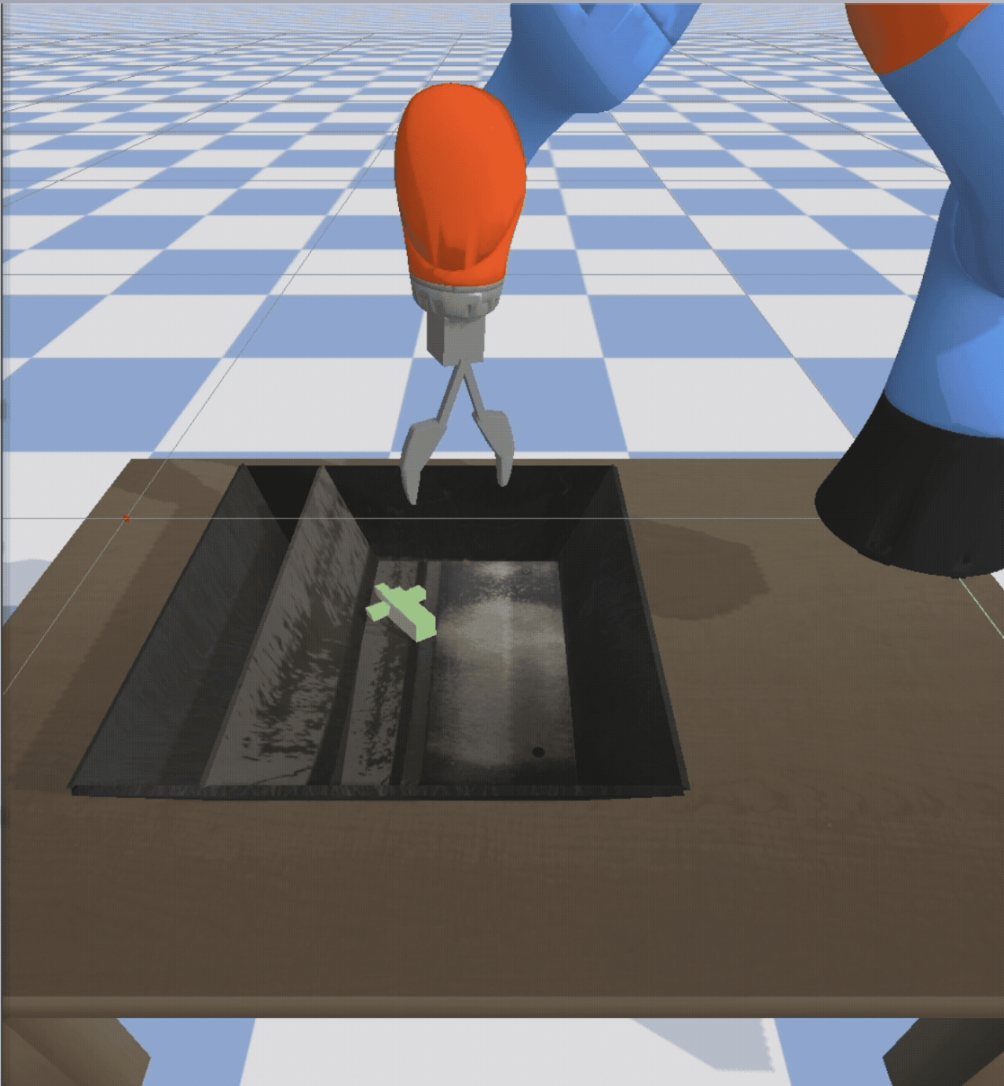
Implemented and trained a PPO policy in PyTorch for 7-DOF robotic grasping in PyBullet, including the clipped surrogate objective, Generalized Advantage Estimation (GAE), experience collection, and model checkpointing.
6-DOF Reusable Launch Vehicle GNC | GitHub
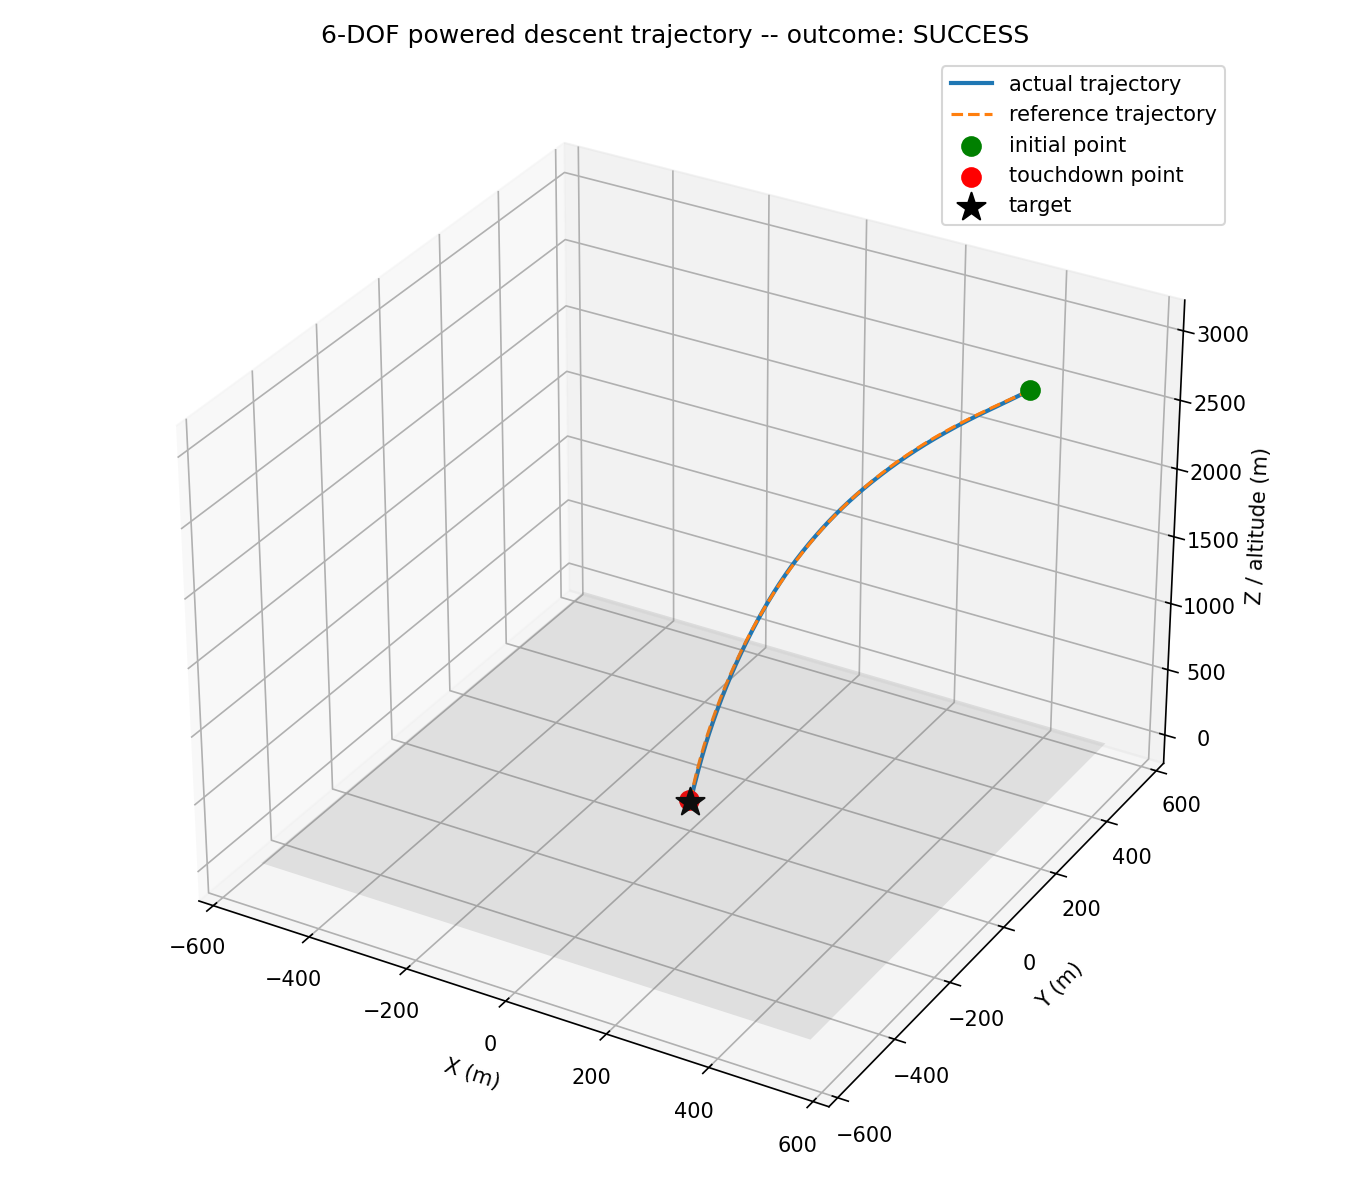
Developed a nonlinear 6-DOF powered-descent GNC stack integrating rigid-body dynamics, Kalman-filter state estimation, trajectory guidance, and quaternion attitude control, achieving a 78% autonomous landing success rate across 150 randomized Monte Carlo trials.
LIDAR-Based Simultaneous Localization and Mapping (SLAM)
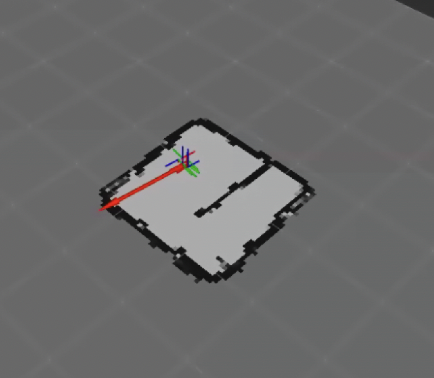
Implemented particle-filter SLAM in C++ and ROS2 using probabilistic motion and LiDAR sensor models, low-variance resampling, ray tracing, and log-odds occupancy mapping for simultaneous localization and environment reconstruction.
2D Path Planning Using A* | GitHub
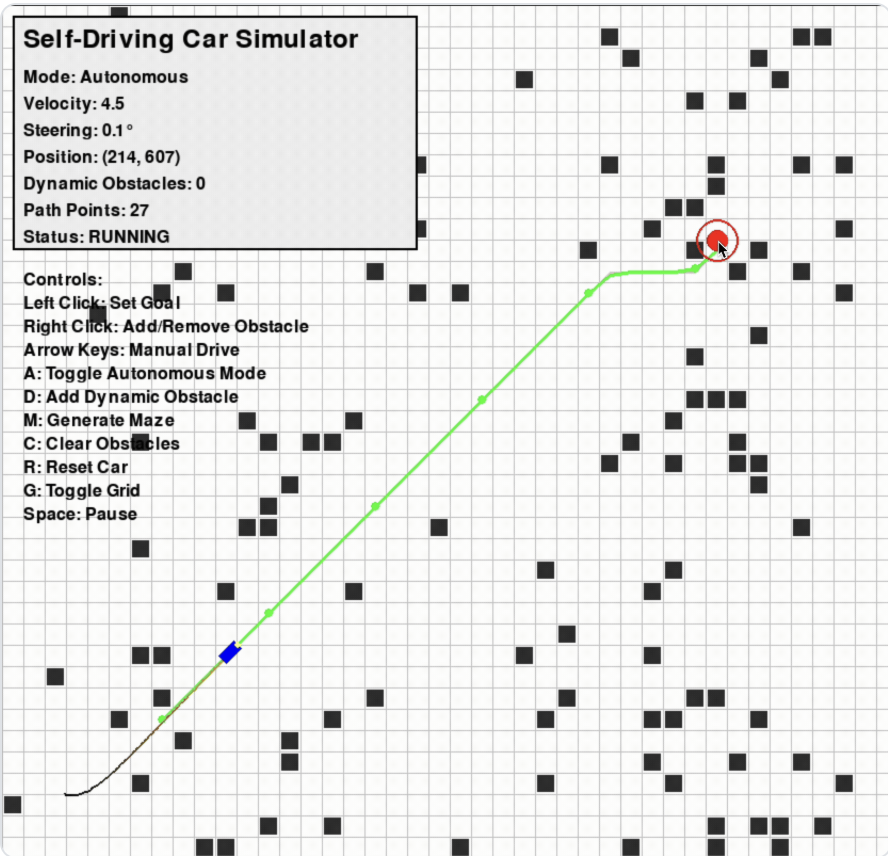
Built an interactive autonomous-driving simulator combining A* path planning, obstacle-aware path smoothing, vehicle dynamics, and path tracking to navigate user-defined environments and obstacles.
[IN PROGRESS] Reinforcement Learning for Humanoid Backflipping
Developing a reinforcement-learning policy for the Unitree G1 in MuJoCo, with a focus on reward shaping for jumping, backflipping, stable landing, and recovery.
Always looking to chat!
University Email: nkreddy [at] umich [dot] edu
Personal Email: nitkred [at] gmail [dot] com
LinkedIn: linkedin.com/in/nitkred
X: @nitkred